
Technology
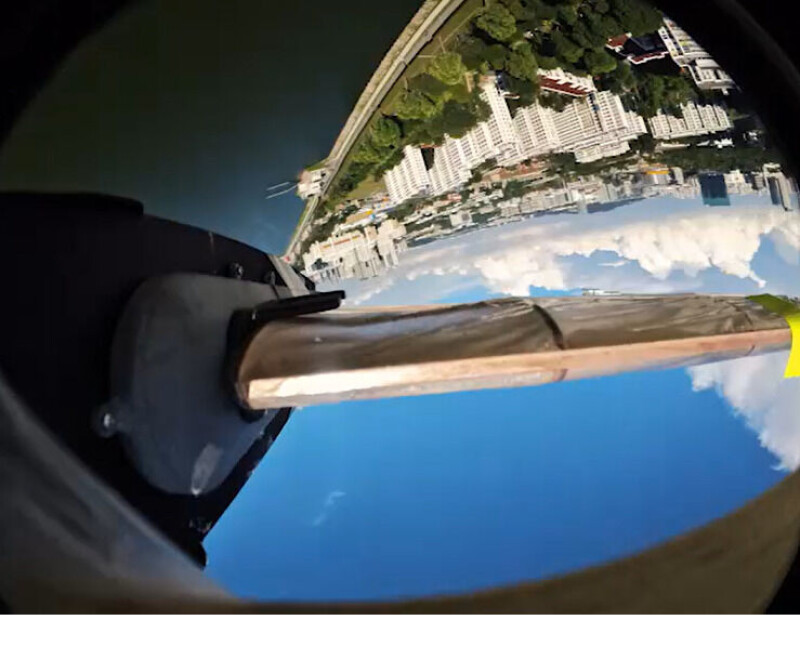
It's a bird, it's a plane...well, more of a spinning parachute, but really it's a droppable robot boat
Key Points
The ALBATROSS, a sailboat drone prototype developed by researchers at Singapore University of Technology and Design (SUTD), lacks the aerial grace of its avian namesake. It doesn't so much fly as plummet – an unsettling start to a sea launch, more so because it's designed to spin like a maple leaf seed as it descends. The sailboat drone's rotation slows its fall and minimizes its impact with the water.
The ALBATROSS, a sailboat drone prototype developed by researchers at Singapore University of Technology and Design (SUTD), lacks the aerial grace of its avian namesake. It doesn't so much fly as plummet – an unsettling start to a sea launch, more so because it's designed to spin like a maple leaf seed as it descends. The sailboat drone's rotation slows its fall and minimizes its impact with the water. This eliminates the engineering challenge of implementing hardware for two modes of mobility. There's no need for landing gear, actuators, or sensors to manage both flying and floating. Watch and download graphics and videos of ALBATROSS here. Developed by SUTD researchers Shane Kyi Hla Win, Danial Sufiyan, Brian Leonard Suhadi, Luke Soe Thura, Xinyu Cai, Wei Jun Ang, and Shaohui Foong, the ALBATROSS represents an achievement in both acronym construction and engineering. The Airborne Lander with Buoyant AuToROtating Sailing Sensor is described in a Science paper as a hybrid robotic system that combines a bio-inspired design for controlled aerial descent with autonomous sailing. Beyond the bio-inspired operation of the rigid wingsails for creating aerodynamic lift during descent and propulsion on the water, the ALBATROSS further cribs from nature's bag of tricks with a rudder that acts like a caudal fin – it moves side to side like a tailfin to generate thrust. And it does so with just three actuators and three primary sensors. Practically, the boat drone, which weights 1.107 kg, was built to fill the gap between expendable aircraft-deployed ocean instruments and floating robots deployed from ships or shore. Its light weight and adaptability make it well suited for rapid aerial deployment followed by energy-efficient persistence on the water, as might be required to monitor an oil spill or time-sensitive weather events. It is intended to be an alternative to large automated sailboats like Saildrone and Sailbuoy that may require ground- or ship-based management. And it has far greater deployment range than hybrid aquatic micro aerial vehicles: more than 100 km, compared to about 7 km for SailMAV, or so its makers claim. "Building on prior work on guided autorotation, ALBATROSS is designed to be released from an aircraft or UAV, passively enter autorotation for a controlled, low-impact water landing, self-right without actuation, and seamlessly transition into a wind-powered sailboat," the researchers explain. "Unlike many hybrid aerial-marine systems, ALBATROSS eliminates the need for aerial propulsion, complex mechanical reconfiguration, or active stabilization during the air-water transition and can sail back to shore at the end of a mission." The prototype takes flight amid a market doing the same. Last year, PwC's Strategy& consultancy issued a report [PDF] that forecasts a sea drone market worth €18.9 billion (~$21.2 billion) by 2030, based on a compounded annual growth rate (CAGR) of 15.5 percent. By the end of the decade, most of that (84 percent) is expected to be for civilian uses like scientific research, commercial, recreational, and engineering applications, and search and rescue operations. ®
ALBATROSS (ORG)
Singapore University of Technology and Design (ORG)
SUTD (ORG)
Shane Kyi (PERSON)
Danial Sufiyan (PERSON)
Brian Leonard Suhadi (PERSON)
Luke Soe Thura (PERSON)
Xinyu Cai (PERSON)
Wei Jun Ang (PERSON)
Shaohui Foong (PERSON)
The Airborne Lander (ORG)
Buoyant AuToROtating Sailing Sensor (LOCATION)
Science (ORG)
Saildrone (ORG)
Sailbuoy (PERSON)